05 / 10 · Computer vision · PepsiCo · Hardware co-design
Stereo-Vision Door State Detection
A depth-based stereo-vision algorithm in OpenCV and C++ that infers a vending machine’s door state, replacing error-prone RF sensors. It eliminated field service calls and cut hardware BOM cost by 20%.
- 20%
- hardware BOM cost cut
- RF → depth
- sensor replaced
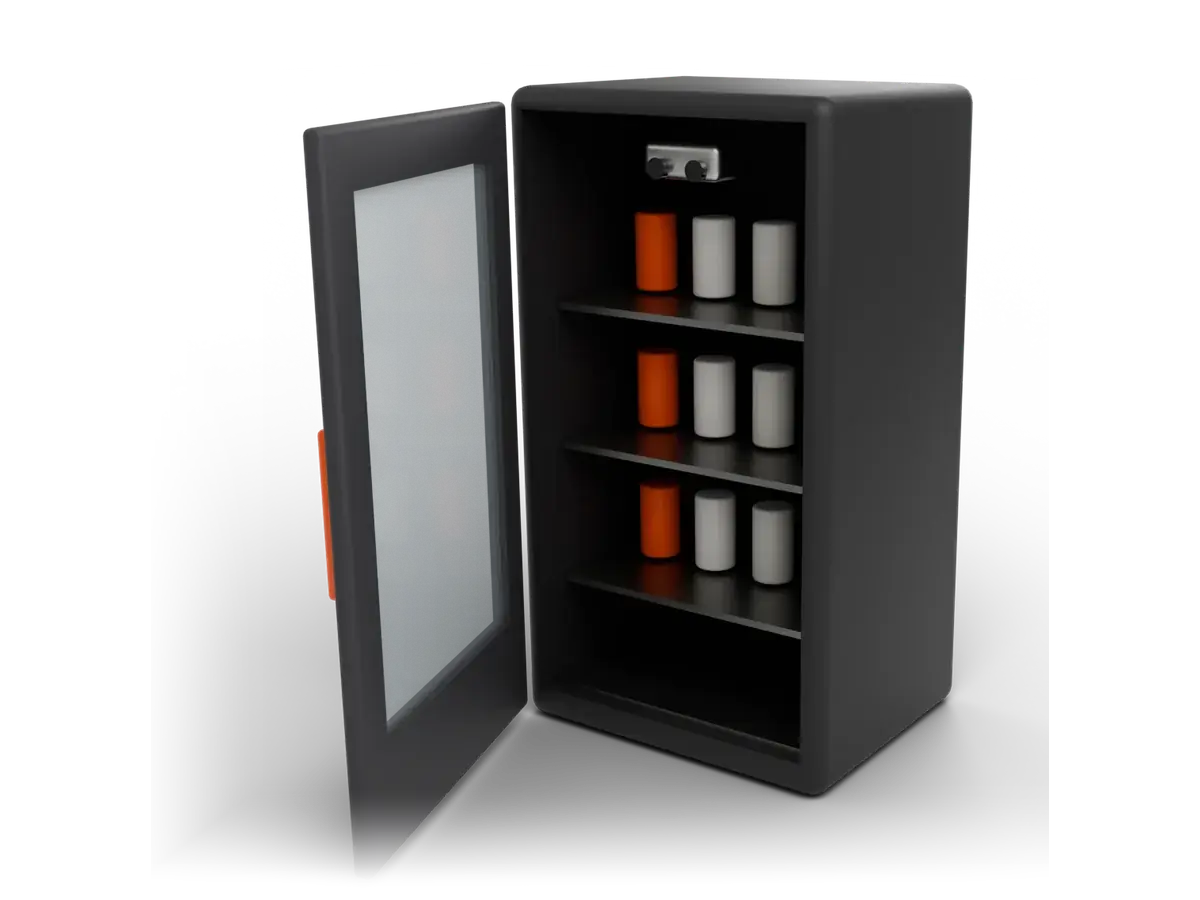
Fig. 01
Try it
AI-generated voice and avatar
01
Problem & approach
The problem
The RF door sensors were error-prone in the field, and every failure meant a service call and a machine that couldn’t tell whether its door was open.
The approach
Hardware-software co-design: give the job to the stereo cameras already inside the machine. A depth-based algorithm in OpenCV and C++ reads the door plane and infers its state.
02
How it works
- The problemError-prone RF sensors were causing field service calls, so the cameras already inside the machine were given the job.
- Depth mapThe stereo pair produces a depth map of the door plane.
- Infer the stateA depth-based algorithm in OpenCV and C++ infers open or closed in real time.
- ImpactIt eliminated field service calls, relaxed OEM assembly tolerances and cut hardware BOM cost by 20%.
03
Results & stack
- 20%
- hardware BOM cost cut
- RF → depth
- sensor replaced
- C++
- OpenCV
- Stereo vision
- Depth mapping